CyberView
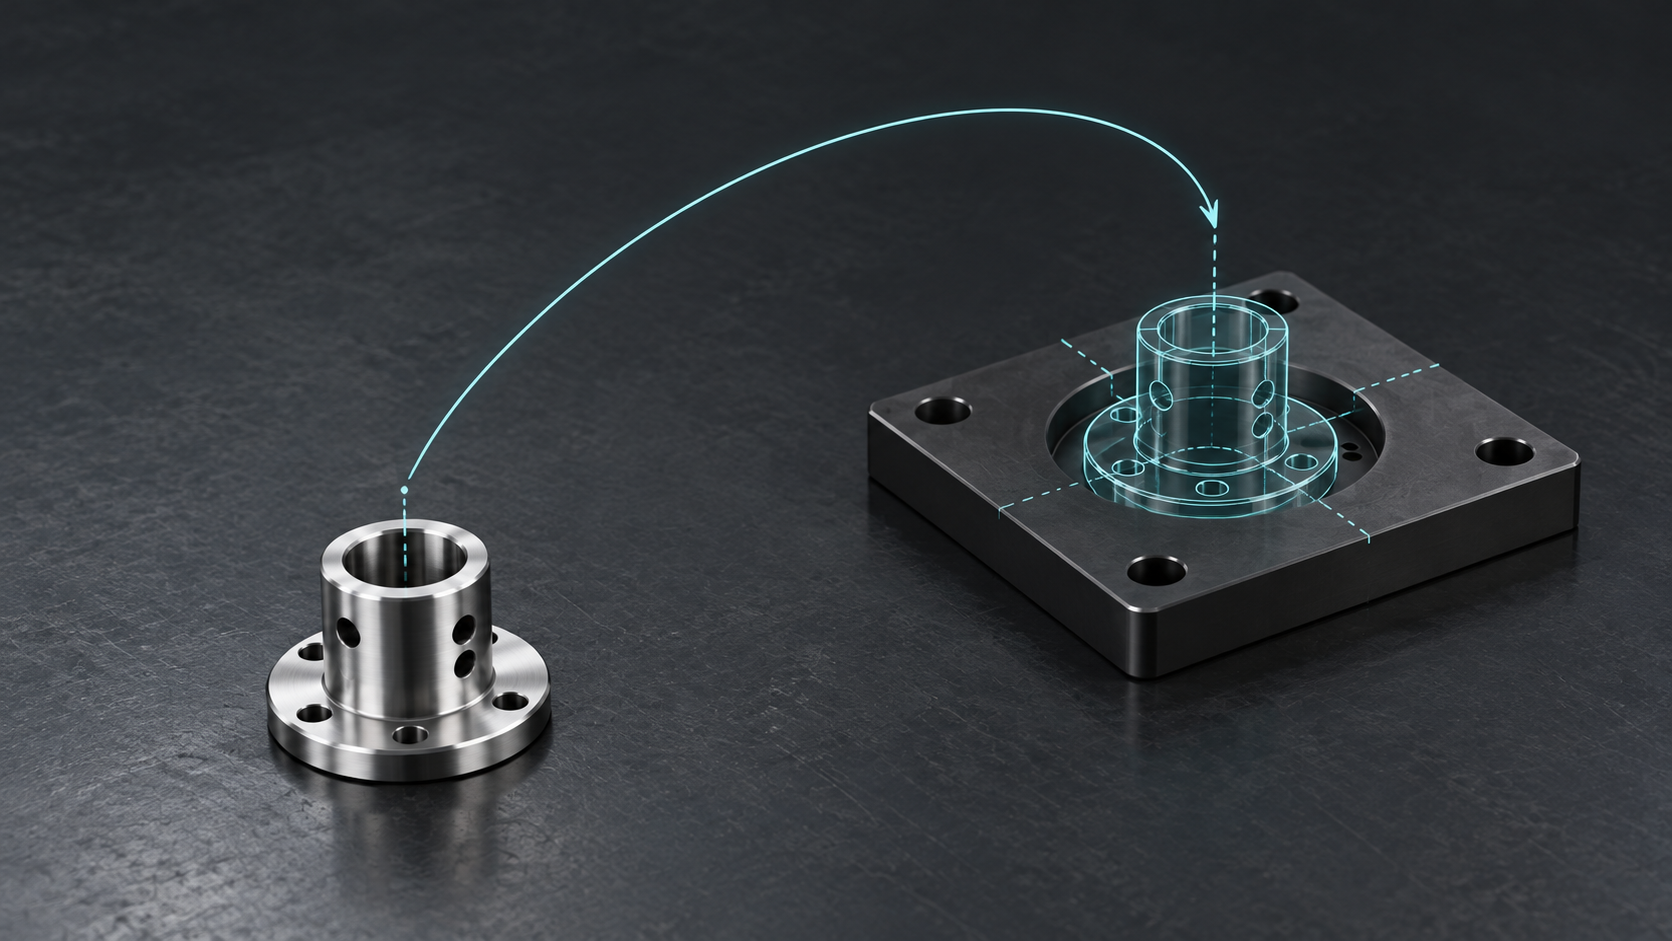
Understand objects in three dimensions: their shape, position, and relationships. Spatial reasoning helps the robot determine how to grasp and manipulate them.
- 3D understanding
- Object relationships
- Spatial reasoning
Technology
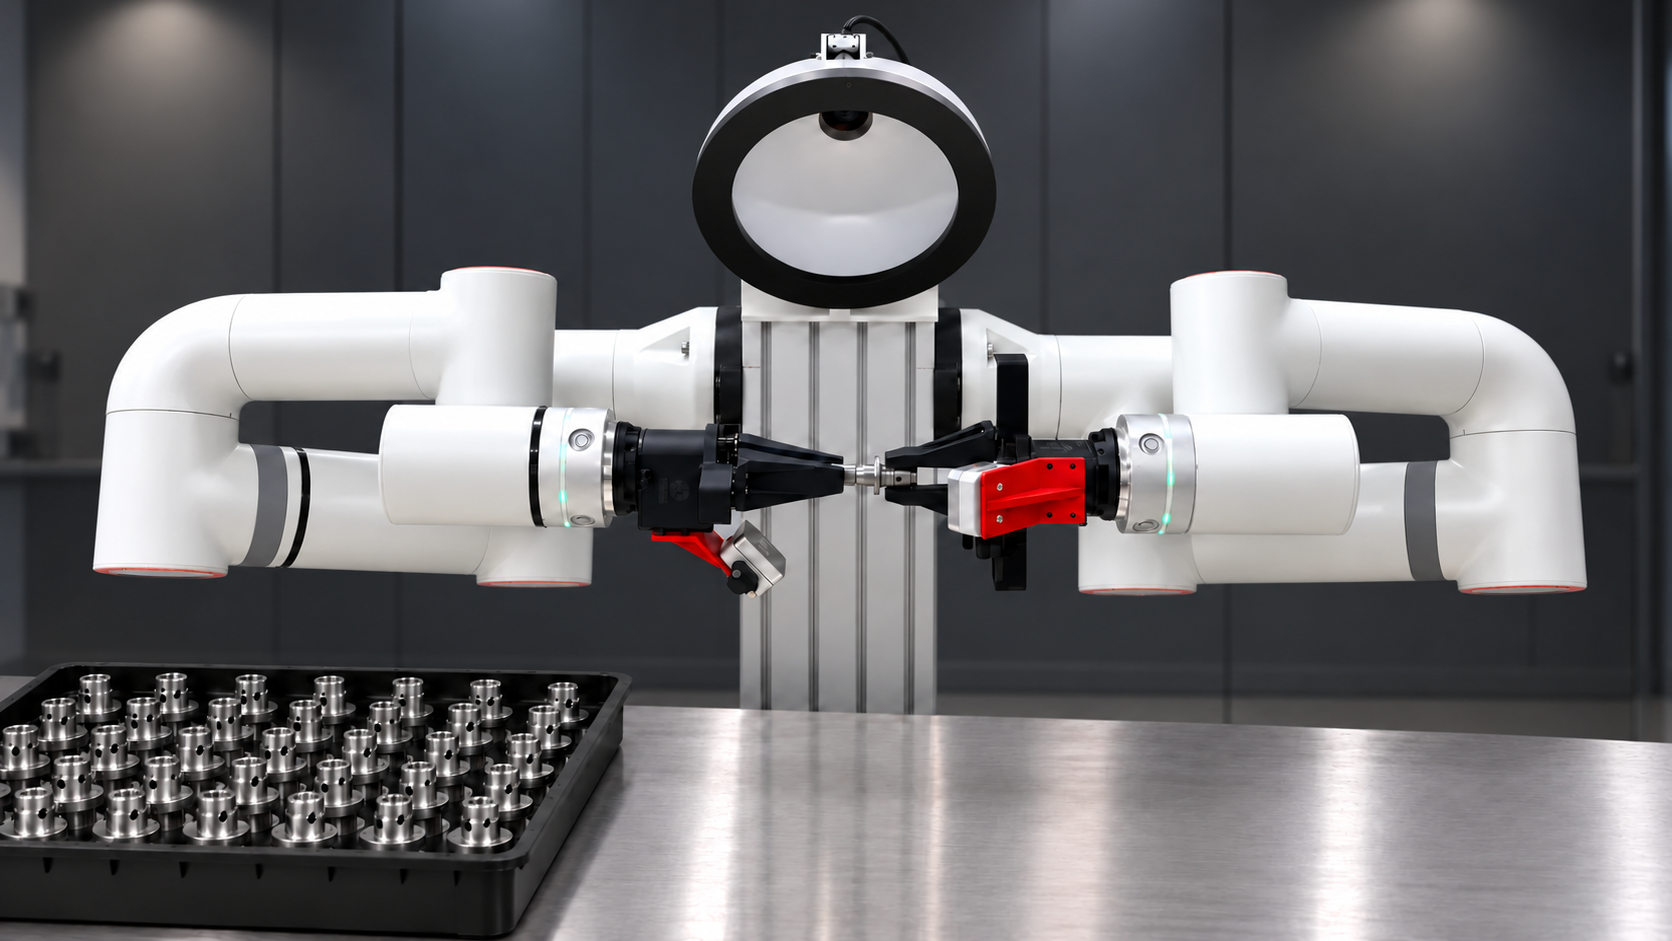
Cyberbrain turns task instructions into physical actions. Its perception, reasoning and execution system powers the industrial workstation and other robot types.
Cognitive architecture
Select perception, reasoning or execution to see its role.
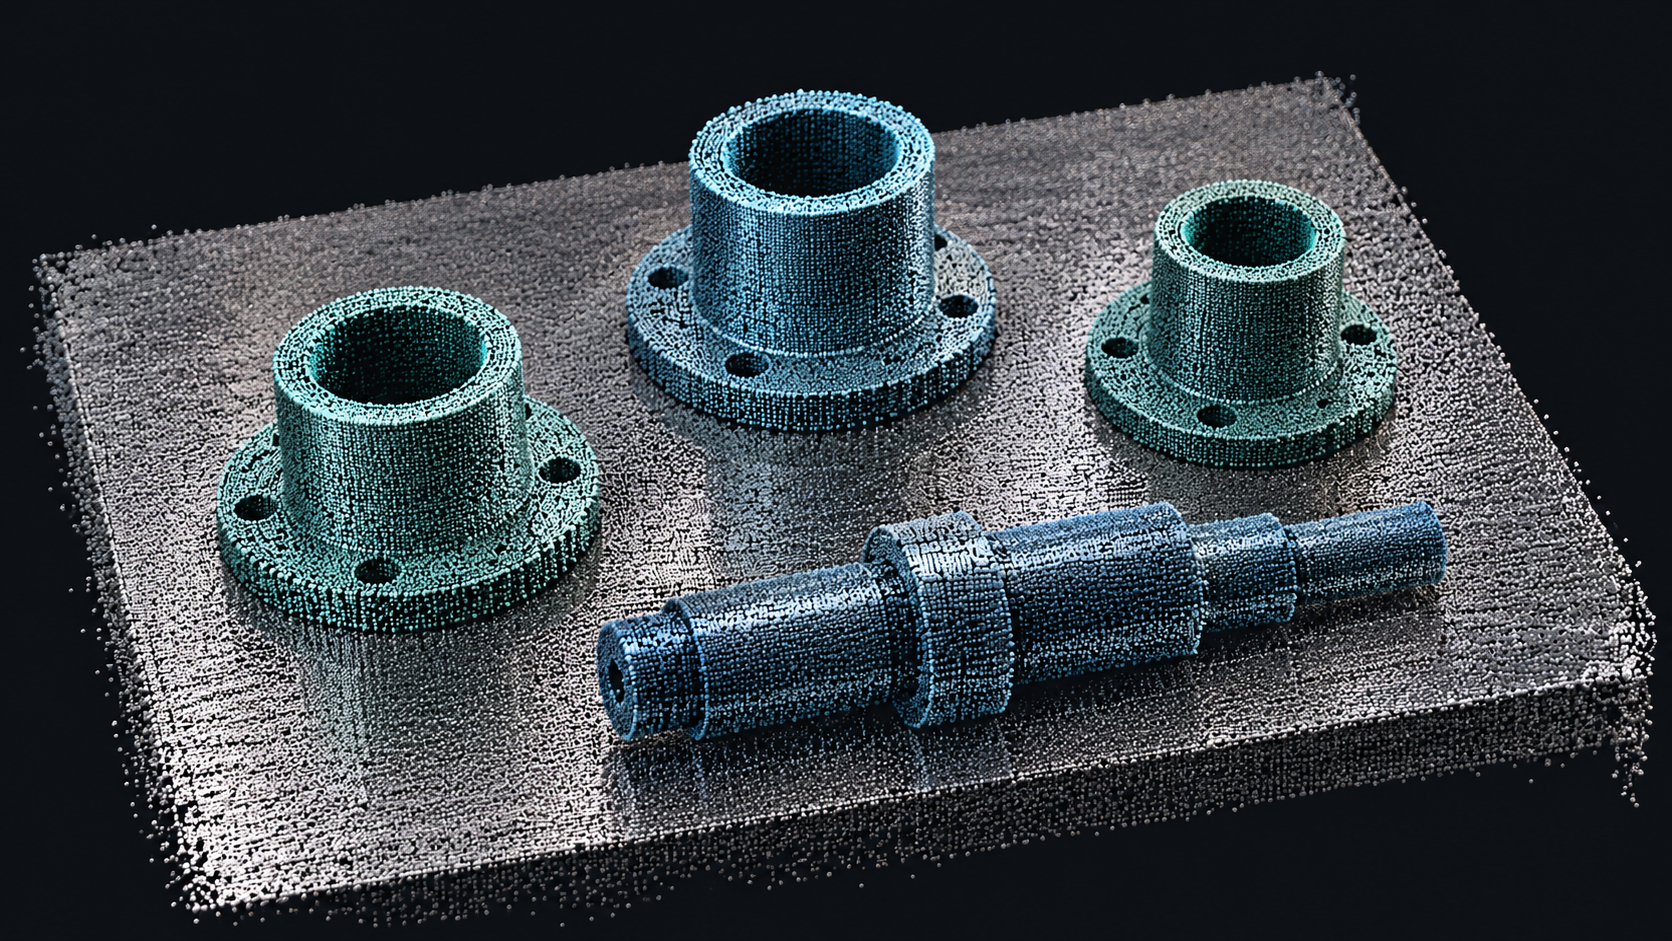
Understand 3D scenes and locate where to act.
Execution feedback informs the next action.
Learn from work instructions or demonstration videos and retain task skills. Programs execute stable workflows; the model replans when conditions change.
CYBERVIEW
CyberView represents objects and their relationships in three dimensions, providing context for manipulation and task reasoning.
Understand 3D scenes and locate where to act.
Interpret goals and constraints, then choose the next action.
Use learned skills and tools through device interfaces.
Understand objects in three dimensions: their shape, position, and relationships. Spatial reasoning helps the robot determine how to grasp and manipulate them.
Turn a task goal into a sequence of actions. The agent calls tools, executes the plan, and uses live feedback to adjust its next step.
Learn tasks from work instructions or demonstration videos, with corrections from operators. Stored programs run stable workflows; the model replans when conditions change.
Our direction
Our industrial workstation is the starting point for cognitive software that can serve different tasks and robot types.
Five-year goal
Extend the workstation to multiple factory tasks, serving manufacturers expanding production in the U.S., including those reshoring operations. Reuse skills and interfaces, coordinate equipment, and expand through industrial partners.
Ten-year vision
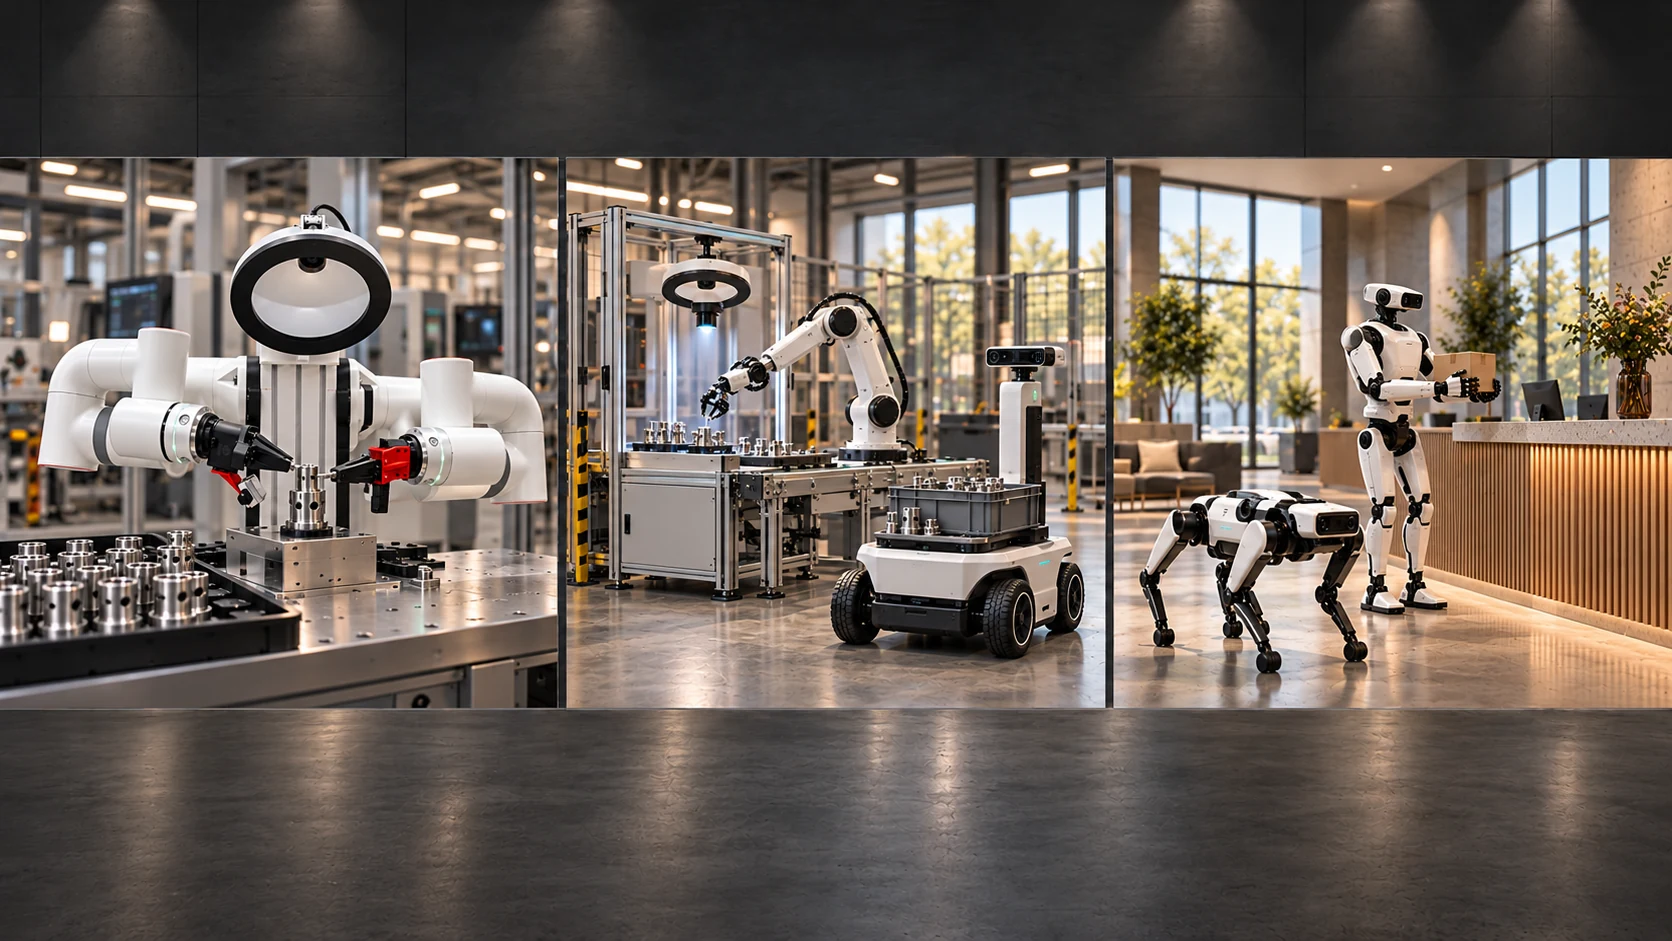
Extend the same cognitive system across robot types and environments, from factories to logistics and other physical work.
Future applications
General-purpose physical intelligence is our long-term goal. Manufacturing is our starting point; broader applications will build on shared skills, experience, and device interfaces.
06 / Work with us
Contact us about workstation tasks, production requirements or robot integration.